
DuoMorph: Synergistic Integration of FDM Printing and Pneumatic Actuation for Shape-Changing Interfaces
Abstract: We introduce DuoMorph, a design and fabrication method that synergistically integrates Fused Deposition Modeling(FDM) printing and pneumatic actuation to create novel shape-changing interfaces. In DuoMorph, the printed structures and heat-sealed pneumatic elements are mutually designed to actuate and constrain each other, enabling functions that are difficult for either component to achieve in isolation. Moreover, the entire hybrid structure can be fabricated through a single, seamless process using only a standard FDM printer—including both heat-sealing and 3D/4D printing. In this paper, we define a design space including four primitive categories that capture the fundamental ways in which printed and pneumatic components can interact. To support this process, we present a fabrication method and an accompanying design tool. Finally, we demonstrate the potential of DuoMorph through example applications and performance demonstrations.
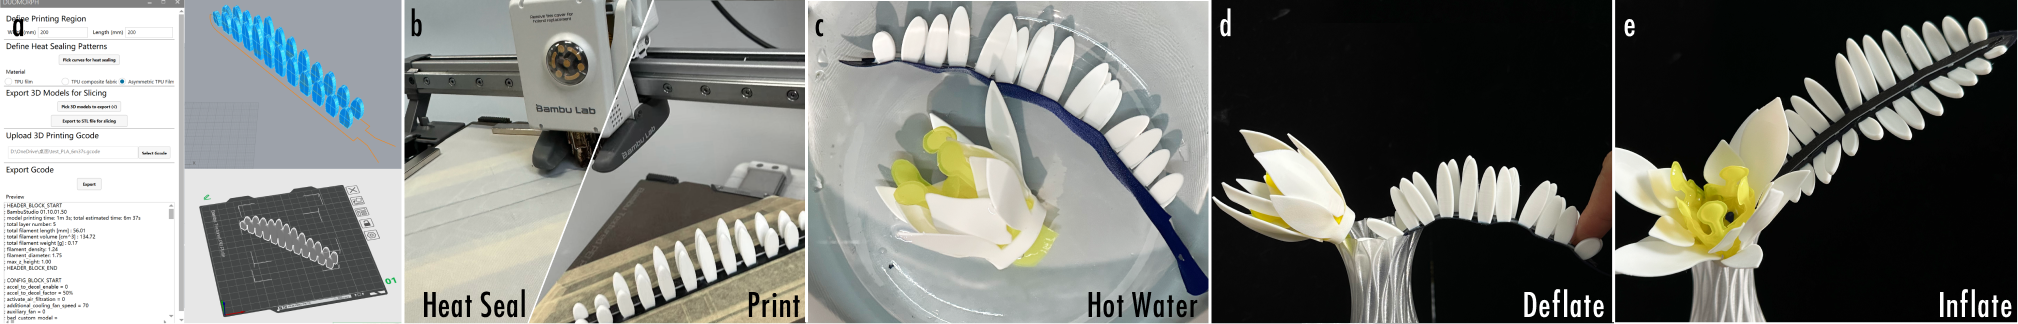
DuoMorph overview. (a) Design tool for modeling and generating integrated G-code; (b) Fabrication of heat-sealed pneumatic actuators (left) and subsequent printing of structures directly on top (right) using an FDM printer; (c) Preshaping the pneumatic actuator with 4D-printed structures in hot water; (d, e) A mimosa-inspired interactive sculpture that folds when touched and blooms when left alone. The flower is also fabricated through a same process.